

A convex polyhedron can be defined algebraically as the set of solutions to a system of linear inequalities
 |
(1)
|
where  is a real
 matrix and
 is a real
 -vector. Although usage varies,
most authors additionally require that a solution be bounded for it to qualify as
a convex polyhedron. A convex polyhedron may be obtained from a finite
set of points by computing the convex
hull of the points. The surface
defined by a set of inequalities may be visualized using the command RegionPlot3D[ineqs,
 x, xmin, xmax
 ,
 y, ymin, ymax
 ,
 z, zmin, zmax
 ]. The method of vertex enumeration
(Fukuda and Mizukoshi) can also be used to determine the faces
of the resulting polyhedron directly.
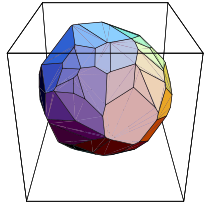
An example of a convex polyhedron is illustrated above (Fukuda and Mizukoshi). A simpler example is the regular dodecahedron,
which is given by a system with  . Explicit examples are given in the following table.
| convex polyhedron |  |  |  |
| regular tetrahedron | 4 |  |  |
| cube | 6 |  |  |
| regular octahedron | 8 |  |  |
In general, given the matrices, the polyhedron vertices (and faces) can be found using an algorithmic procedure known as vertex enumeration.
Geometrically, a convex polyhedron contains the line segment joining any two of its points, including points on its boundary. The 92 nonuniform convex polyhedra having only regular polygons as faces are called Johnson solids. They exclude the Platonic solids, Archimedean solids, prisms, and antiprisms (Johnson 1966).
The volume of a bounded three-dimensional convex polyhedron can be computed by triangulating its faces and joining each
resulting triangle to an interior point  . If
 ,
 , and
 are the vertices of
each such triangle, then
 |
(2)
|
This sums the volumes of the resulting tetrahedra (Franklin).
Every bounded three-dimensional convex polyhedron can be represented in the plane or on the surface of a sphere
by a 3-connected planar graph (called a polyhedral
graph). Conversely, by a theorem of Steinitz as restated by Grünbaum, every
3-connected planar graph can be realized as a convex
polyhedron (Duijvestijn and Federico 1981). The numbers of vertices  , edges
 , and faces
 of a bounded three-dimensional convex
polyhedron are related by the polyhedral formula
 |
(3)
|

 Fukuda, K. and Mizukoshi, I. "Vertex Enumeration Package for Convex
Polytopes and Arrangements."