


The detour matrix  ,
sometimes also called the maximum path matrix or maximal topological distances matrix,
of a graph is a symmetric
matrix whose
 th
entry is the length of the longest path from vertex
 to vertex
 , or
 if there is no such path (Harary 1994, p. 203). The
most common convention (and that adopted here) is to take
 .
For a connected graph, every path extends to a spanning tree. Its detour matrix can
therefore be computed from the distance matrices
of all its spanning trees as  , where
 ranges over the spanning trees
and
 is the graph
distance in
 (Harary 1994, p. 203).
For a graph with vertex count  , a detour matrix element of
 corresponds to a Hamiltonian
path between vertices
 and
 . A graph having a detour matrix
whose off-diagonal elements are all equal to
 is therefore Hamilton-connected.
Similarly, a bipartite graph whose elements
 are maximal for all
 and
 corresponding to different elements of the bipartition
is Hamilton-laceable.
For a complete multipartite graph with positive part sizes  ,
 , put
 . If distinct endpoints
 and
 belong to parts
 and
 , and
 counts how many of these endpoints belong to part
 , then
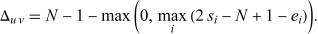 |
Occurrences of a part on a path require separating vertices from other parts, which gives the upper bound. Delete the indicated number of vertices from a part with maximum deficit. The retained
part counts  satisfy
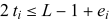 ,
where
 .
A connected loopless multigraph on the parts with
degrees
 has an Eulerian path
with the prescribed endpoint parts. Its sequence of parts yields a path
attaining the bound. Such a multigraph exists because
no prescribed vertex degree exceeds half their sum.
Only the endpoint parts can have odd vertex degree.
Components can therefore be joined by degree-preserving
edge switches before taking the Eulerian path.
Precomputed detour matrices for many named graphs are available in the Wolfram Language as GraphData[graph, "DetourMatrix"].
