

A structure tensor is a matrix formed from outer products of image gradient vectors
to describe local directional variation. For a real scalar
image  ,
write
 for its gradient. The pointwise structure tensor is
 , where the superscript
 denotes the transpose.
A neighborhood-averaged version is
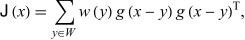 |
where  is a neighborhood and
 are weights with
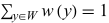 (Schultz et al. 2009).
The structure tensor is a real symmetric matrix and a positive semidefinite matrix. Its eigenvectors identify principal directions of intensity variation, and the corresponding eigenvalues measure variation in those directions. The two-dimensional case used in corner detection is the Harris matrix.
