

The controllability matrix for the constant-coefficient system of ordinary differential equations 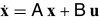 , with
 state variables and
 inputs, where
 and
 are positive integers,
is the
 block matrix
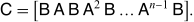 |
The column space of  consists of the states reachable from the zero state. The
system is controllable, meaning that any initial state can be driven to any final
state by a suitable input over a finite time interval,
iff
 has matrix rank
 (Massachusetts Institute of Technology 2010, pp. 10-1-10-2).
For example,  and
 give
 |
which has matrix rank 2, so the system is controllable.
The same block matrix is also called a reachability matrix in control theory. This usage is distinct from the reachability matrix of a directed graph.
The Wolfram Language computes the controllability matrix of such a state-space model using ControllabilityMatrix[ssm].
