

The scallop theorem states that a freely swimming body undergoing a reciprocal deformation in Stokes flow cannot achieve a net translation or rotation over a complete cycle. A reciprocal deformation retraces the same sequence of shapes in reverse order, possibly at a different speed. The theorem assumes an incompressible Newtonian fluid, negligible inertia of both fluid and swimmer, no externally applied force or torque, a fluid at rest at infinity, and equality of the fluid and body velocities at the body surface (Purcell 1977, Ishimoto and Yamada 2012).
If  and
 describe the body's position and orientation, with
 a rotation matrix, a
reciprocal cycle of duration
 satisfies
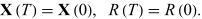 |
The linearity and reversibility of the steady Stokes flow equations imply that reversing a shape change reverses the instantaneous rigid-body motion. The return stroke therefore undoes the translation and rotation of the outward stroke, independently of the rates at which the strokes are performed.
A scallop with a single hinge provides the motivating example: opening and closing the hinge retraces one shape path. Nonreciprocal deformation is necessary, but not sufficient, for propulsion under these hypotheses. With nonnegligible inertia or a non-Newtonian fluid, the conclusion need not hold.
