


A pursuit curve is the path traced by a point  that is always directed toward a point
 moving along a known curve,
when
 and
 move with uniform speeds. Pursuit curves
were considered in general by the French scientist Pierre Bouguer in 1732, and subsequently
by the English mathematician Boole.
Under the name "path minimization," pursuit curves are alluded to by math genius Charlie Eppes in the Season 2 episode "Dark Matter" of the television crime drama NUMB3RS when considering the actions of the mysterious third shooter.
The equations of pursuit are given by
 |
(1)
|
which specifies that the tangent vector at point  is always parallel to the line
connecting
 and
 , combined with
 |
(2)
|
which specifies that the point  moves with constant speed (without loss of generality, taken
as unity above). Plugging (2) into (1) therefore
gives
 |
(3)
|
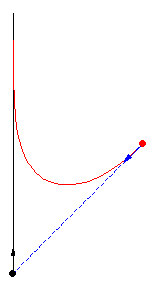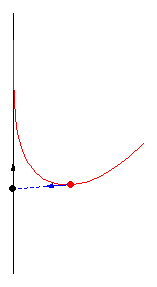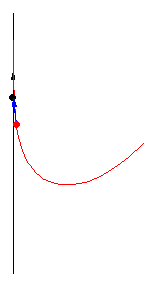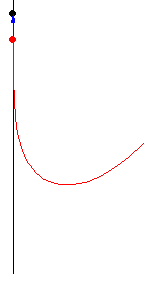
The case restricting  to a straight line was studied by Arthur Bernhart (MacTutor
Archive). Taking the parametric equation
 and
 , suppose that both points
move at unit speed and that
 starts at
 with
 . The case
 follows by reflection.
The equations of motion are
 |
(4)
|
and
 |
(5)
|
Squaring and rearranging (4) gives
 |
(6)
|
Expanding gives
 |
(7)
|
which can be simplified using (5) to
 |
(8)
|
But this is a perfect square,
 |
(9)
|
so taking the square root of both sides gives
 |
(10)
|
This equation can be converted into one for  as a function of
 by dividing both sides by
 , giving
 |
(11)
|
where  .
Since
 decreases during the pursuit, the arc length traveled
by
 from its initial position is
 |
(12)
|
since  is a constant for this problem, so (11) becomes
 |
(13)
|
Differentiating then gives a second-order ordinary differential equation
 |
(14)
|
that can be solved analytically to yield
 |
(15)
|
Here  is real and
 for the stated differential equation on
 . The two constants are fixed by the initial
conditions.
The initial conditions for a particle starting at  at time
 are given by
 |  |  |
(16)
|
 |  |  |
(17)
|
Plugging these into (15), solving for  and
 , and plugging the results back into (15)
gives the full solution
 |
(18)
|
where
 |  |  |
(19)
|
 |  |  |
(20)
|
If  , the
 -component of
 's motion initially decreases and then increases. The minimum
of
 is found by differentiating (18),
setting the derivative equal to 0, and solving for
 . The result is
 |
(21)
|
Plugging in and simplifying gives the corresponding  -coordinate,
 |
(22)
|
For  ,
the minimum occurs at the initial point.
For
 ,
the height increases throughout the pursuit.
It is also possible to express the solution in closed form for  and
 .
Plugging (18) into (11) and solving for
 gives
 |
(23)
|
which can be inverted in terms of the Lambert W-function to obtain
 |
(24)
|
where
 |
(25)
|
Here  is the principal branch. Its argument is positive
because
 ,
and the inversion gives
 for
 .
Plugging this in to the equation for
 then gives
 |
(26)
|
For straight-line pursuit at unequal speeds, Barton and Eliezer (2000, pp. 367-371) give the path as a Cartesian equation for an
arbitrary positive speed ratio. The Lambert  expressions above apply to the equal-speed case.
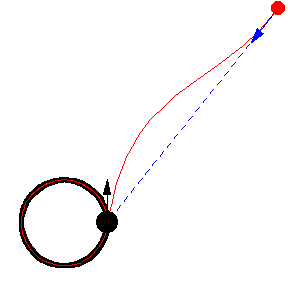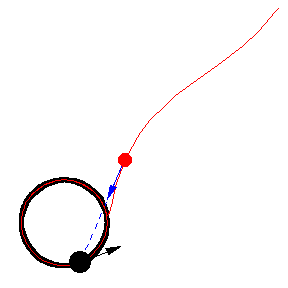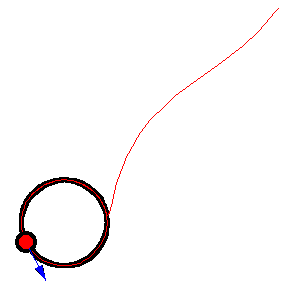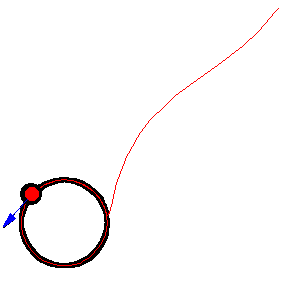
|
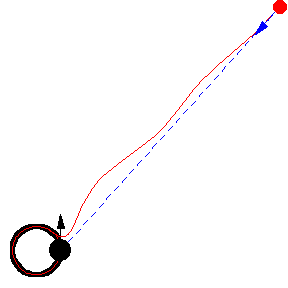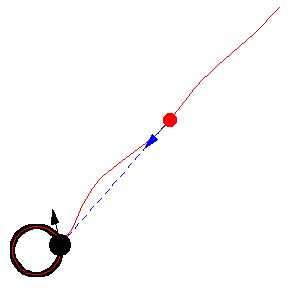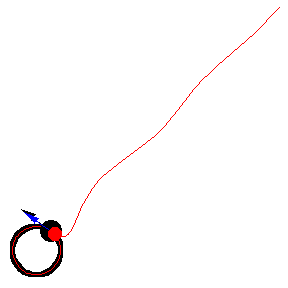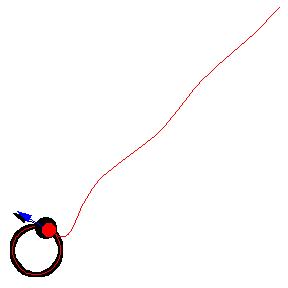
|
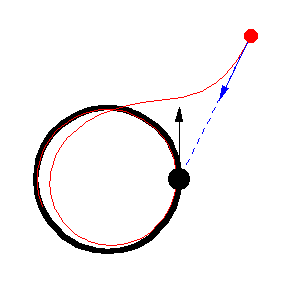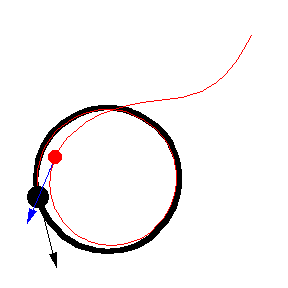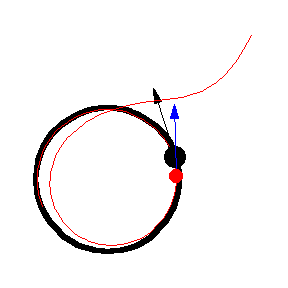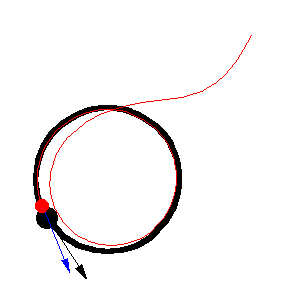
|
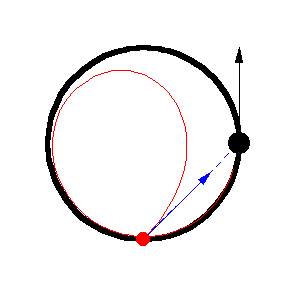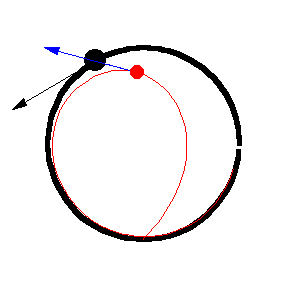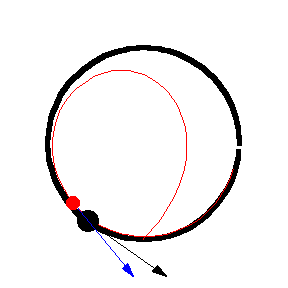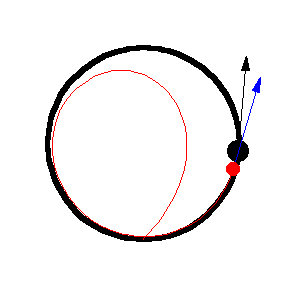
|
The figures above show various pursuit curves for  moving about a circle at constant
speed.
The problem of  mice (or dogs) starting at the corners of a regular
polygon and running towards each other is called the mice
problem.
