

A local isometry between Riemannian manifolds  and
 is a smooth map
 whose restriction near every point
is a diffeomorphism onto an open
set of
 and preserves the metric tensor. Explicitly,
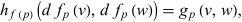 |
where  and
 belong to the tangent space
 at
 , and
 is the tangent map at
 (Burtscher 2025, p. 7). The same
definition applies to pseudo-Riemannian
manifolds using their metric tensors.
For Riemannian manifolds, a local isometry preserves curve length, but need not be injective or preserve global distances (Burtscher 2025, pp. 21-22). For example, the map from the real line to the unit circle with its arc length Riemannian metric, given by
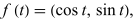 |
is a local isometry because its velocity vector has vector norm 1. However, 0 and  have the same image, so their distance
is not preserved. A local isometry that is also a diffeomorphism
of the whole manifolds is an isometry.
