The endpoint map of a control system sends a trajectory with fixed initial point to its final point. For horizontal curves of a smooth
distribution with , it is .
On the corresponding space of square-integrable controls, its differential describes
the endpoint variations obtainable by infinitesimal control variations (Wang and
Zelenko 2026).
Agrachev, A.; Barilari, D.; and Boscain, U. A Comprehensive Introduction to Sub-Riemannian Geometry: From the Hamiltonian Viewpoint. Cambridge,
England: Cambridge University Press, 2019. https://doi.org/10.1017/9781108677325.Wang,
B. and Zelenko, I. "An Equiregular Counterexample to the Sard Conjecture for
Sub-Riemannian Endpoint Maps." 16 Oct 2026. https://arxiv.org/abs/2610.24080.


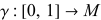 of a smooth
distribution with
 , it is
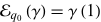 .
On the corresponding space of square-integrable controls, its differential describes
the endpoint variations obtainable by infinitesimal control variations (Wang and
Zelenko 2026).
