

Topological overlap measures how many images of faces of a simplex must cover a common point under a continuous map
to a lower-dimensional Euclidean space (Gromov
2010). For a continuous map  , let
 be the largest number of
 -dimensional faces whose images contain one point. The topological
overlap constant is
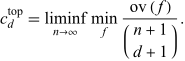 |
Restricting the minimum to affine maps defines  . For affine maps this asks what fraction of
the simplices spanned by a finite point set in general
position must contain one common point, the question underlying the first selection
lemma (Bukh et al. 2010).
Norin (2026) gave a proof that, for every integer  ,
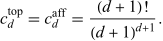 |
The affine equality resolves the conjecture of Bukh et al. (2010). Thus for fixed  every continuous map has a point in the images
of at least
](/images/equations/TopologicalOverlap/Inline7.svg) faces as
 , and the coefficient is optimal even for
affine maps. Norin (2026) credits GPT-6 Astra with finding the proof,
which he rewrote and reorganized. An accompanying Lean formalization is supplied.
