

The moment of inertia with respect to a given axis of a solid body with density  is defined by the volume integral
 |
(1)
|
where  is the perpendicular distance from the axis of rotation. This can be broken into
components as
 |
(2)
|
for a discrete distribution of mass, where  is the distance to a point
(not the perpendicular distance) and
 is the Kronecker delta,
or
 |
(3)
|
for a continuous mass distribution. Depending on the context,  may be viewed either as a tensor
or a matrix. Expanding (3) in terms
of Cartesian coordinates gives the equation
 |
(4)
|
The moment of inertia of a region can be computed in the Wolfram Language using MomentOfInertia[reg].
The moment of inertia tensor  is a symmetric tensor,
and is related to the angular momentum vector
 by
 |
(5)
|
where  is the angular velocity vector.
The principal moments of inertia are given by the entries in the diagonalized moment of inertia matrix, and are denoted (for a solid)
 ,
 , and
 in order of decreasing magnitude. In the frame defined by
the principal axes, the moments are also sometimes
denoted
 ,
 , and
 . The principal axes
of a rotating body are defined by finding values of
 such that
 |
(6)
|
 |
(7)
|
which is an eigenvalue problem.
The following table summarizes the moments of inertia of some common solids of mass  and uniform density around some of their principal
axes. For the cuboid,
 ,
 , and
 are the full side lengths and the axis passes through its
center parallel to the side of length
 .
| solid/axis | moment of inertia |
| cylinder about symmetry axis |  |
| cylinder about central diameter |  |
| ellipsoid about principal axis |  |
| elliptical slab about major axis |  |
| elliptical slab about vertical |  |
| cuboid about principal axis |  |
| ring about perpendicular axis |  |
| ring about diameter |  |
| rod about end |  |
| rod about center |  |
| sphere about diameter |  |
| spherical shell |  |
| torus about diameter | 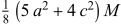 |
| torus about symmetry axis |  |
